Industrial automation
Low backlash rotation for machine tools and robots
A rotary table or a robot base does not need enormous capacity. It needs stiffness, repeatability and a backlash figure that holds after a million cycles.
Where the accuracy actually comes from
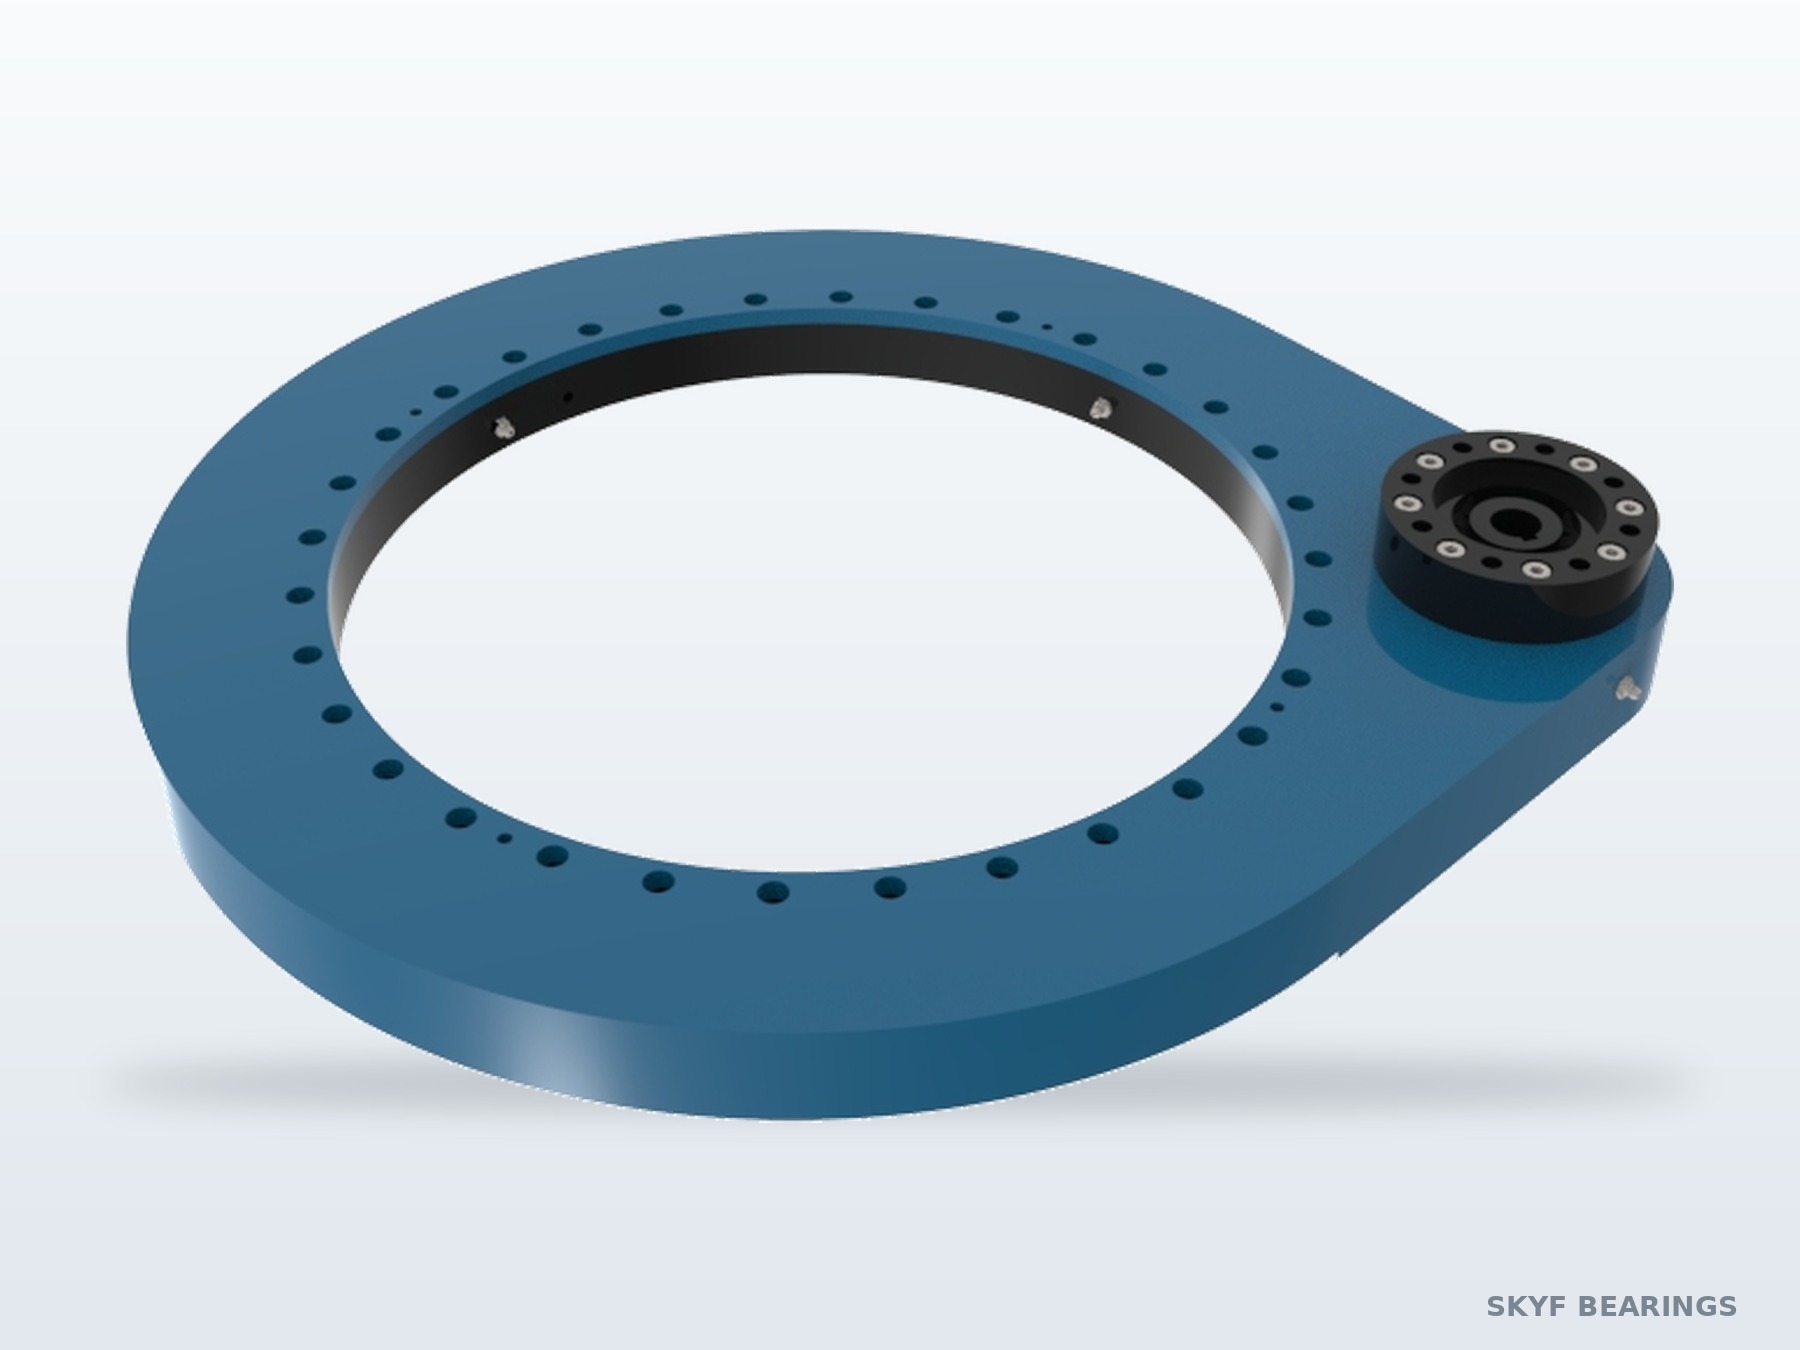
Backlash in a positioning axis is rarely a gear problem at the start of life. It comes from housing deflection under cutting load and from the preload being lost as the raceway beds in. Both are addressed at the assembly stage.
- Crossed roller rings preloaded at assembly
- Housing machined for the actual preload, not the nominal one
- Double worm arrangement where positioning accuracy dominates
Motor and encoder interface
Servo motors are unforgiving about misalignment. We machine the input flange and coupling to the motor drawing so the assembly arrives with the runout already checked.
- Servo flange to the motor drawing
- Encoder mounted at the output, not the input, where the application needs it
- Cable gland orientation matched to the machine layout
Repeatability over life
A backlash figure quoted at delivery means little without a cycle count. We state the measurement method and the number of cycles it was taken after.
Send the positioning requirement
Required backlash, repeatability, table size and motor type are the four figures we need to propose a drive.